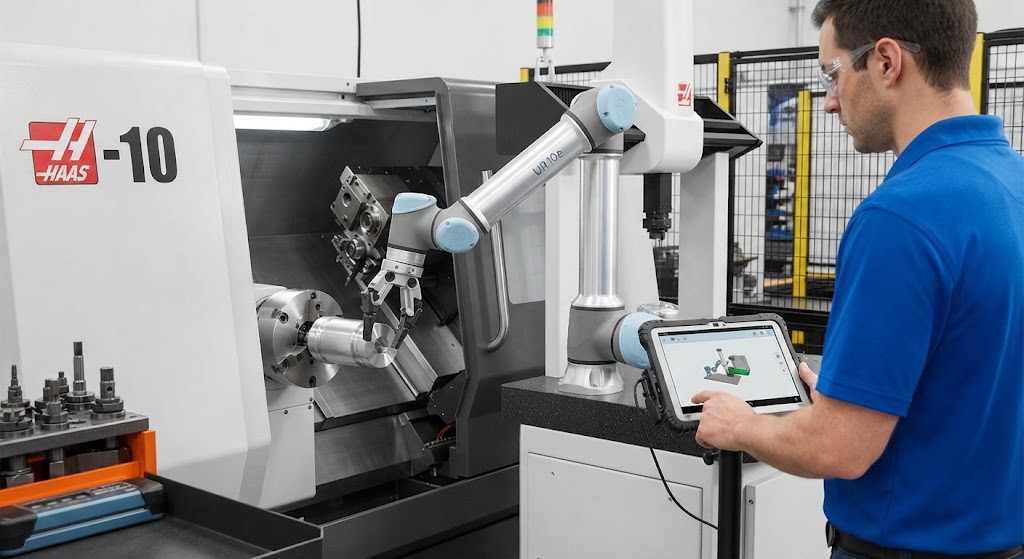
Robotic machine tending uses a robot to load and unload a machine tool or process station. The robot, machine, PLC, tooling, sensors, and safety system work together through a defined handshake and recovery sequence.
Typical cycle
- The robot or PLC confirms the cell is ready and safe.
- Part presence and tooling conditions are checked.
- The robot loads raw material and confirms position.
- The machine completes its operation and signals complete.
- The robot unloads the part and sends it to the next location.
Tooling and part presentation
Reliable tending depends on grippers, part orientation, fixtures, sensors, chip or debris control, and repeatable presentation. Tooling should include feedback where a missed grip or incomplete clamp could damage equipment.
PLC and robot handshake
Signals commonly include cell ready, robot ready, start, busy, complete, fault, part present, machine ready, and permit. The exact names vary, but the principle is consistent: every handoff needs a positive condition, timeout, and recovery state.
Safety and commissioning
Risk assessment, guarding or collaborative controls, emergency stops, access control, safe motion, and restart behavior must be addressed. TechControl provides robot cell design and integration and machine commissioning.
Ready to bring your project to life?
Contact Us